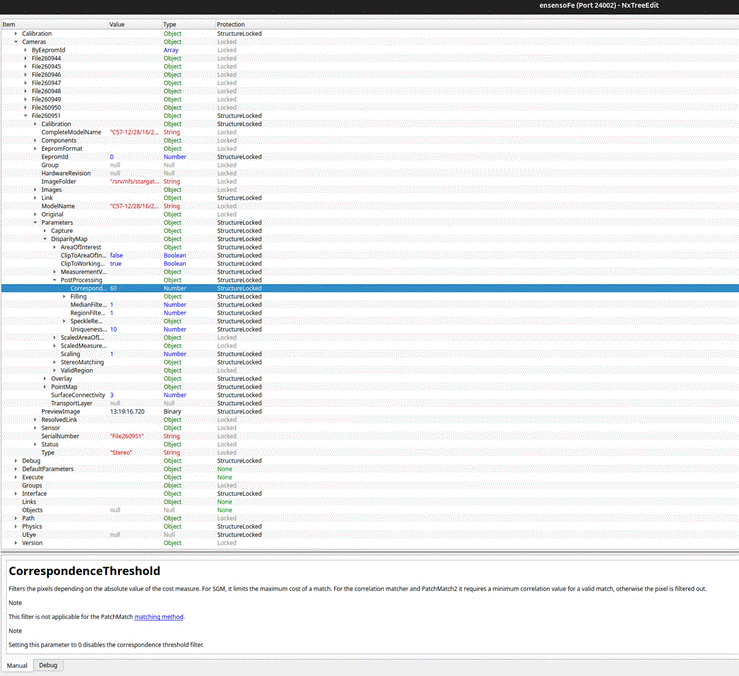
I am trying to set the correspondence Threshold in the on a FileCam using the C API the value is not written since the original values i locked and the variable value is structure locked.
Setting the value not applied with the File Camera open by the C Api..
So which i s the way to set the setting from a programming point of view?
I forgot to mention that structure lock does not mean it is forbidden to change values. It is only forbidden to alter the structure and remove entries or add new ones.
I don’t see why this should not work under linux. I am working on linux myself and executed the provided C code example using a file camera downloaded from the website. Can you outline the code you are using to set the threshold? Perhaps I can help you then. You can also send me a personal message if you dont want to share it in a public forum.
Okay, I think the situation is cleared, the nxLibSet call was using a path where the camera part was missing … so just /paramters/DisparityMap/PostProcessing/CorresponcenceThreshHold.
But instead throw ItemNotExistent the Error Code was no Error. Even more confusing, the Default Value seems to be set to the Open Camera, despite there are different Setting stored with the camera.
Hi, a file camera is always opened with default settings and one has to apply the parameters that are shipped alongside the filecam. You can read the set of parameters shipped with the filecam under "Cameras/<serial>/Original/Parameters" using the nxLibGetJson method and write it to "Cameras/<serial>/Parameters" using the nxLibSetJson method, see Using File Cameras — Guides - Ensenso SDK 4.3.1057 Documentation
I think there was no error since “/paramters/DisparityMap/PostProcessing/CorresponcenceThreshHold” got created.